Qiayuan Liao
I'm a third-year Ph.D. student at UC Berkeley, advised by Koushil Sreenath and Pieter Abbeel.
Previously, I was a research intern at Boston Dynamics, where I was fortunate to work with Scott Kuindersma on reinforcement-learning control for the E-Atlas.
I'm a true full-stack roboticist dedicated to creating general-purpose humanoid systems. Toward this goal, I focus on
(a) agile and robust whole-body loco-manipulation and
(b) co-design of data, hardware, and control.
Scholar
Github
LinkedIn

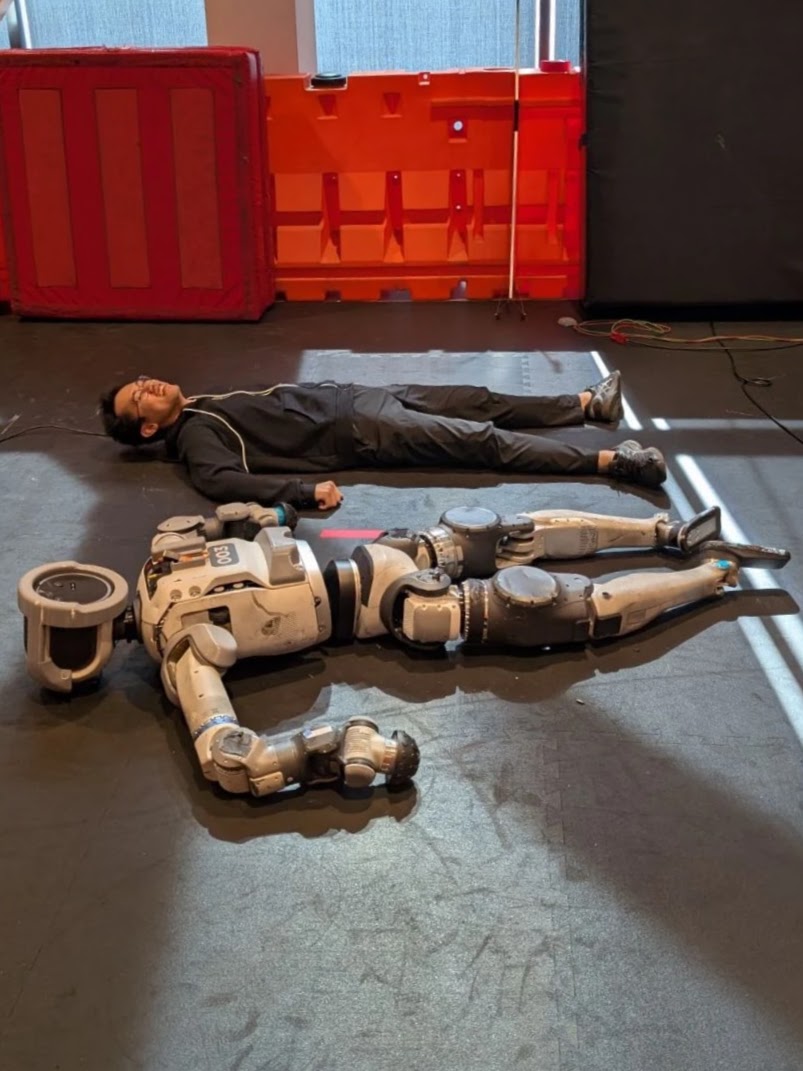
SuperMimic: Scaling Humanoid Whole-Body Control with One Differentiable World Model
Qiayuan Liao, Yiyang Shao*, Junfeng Long*, Kevin Zakka, Roberto Horowitz, Pieter Abbeel†, Koushil Sreenath†
Conference on Robot Learning (CoRL), 2026 (Oral)
Webpage •
Paper •
Video
Workhorse: Learning Robust Whole-Body Humanoid Loco-Manipulation from Human Data
Songbo Hu*, Qiayuan Liao*, Yufeng Chi, Kevin Zakka, Yakun Sophia Shao, Pieter Abbeel, Koushil Sreenath
Webpage •
Paper •
Video
BeyondMimic: From Motion Tracking to Versatile Humanoid Control via Guided Diffusion
Qiayuan Liao*, Takara E. Truong*, Xiaoyu Huang*, Yuman Gao, Guy Tevet, Koushil Sreenath†, C. Karen Liu†
Science Robotics, 2026
Webpage •
Paper •
Code
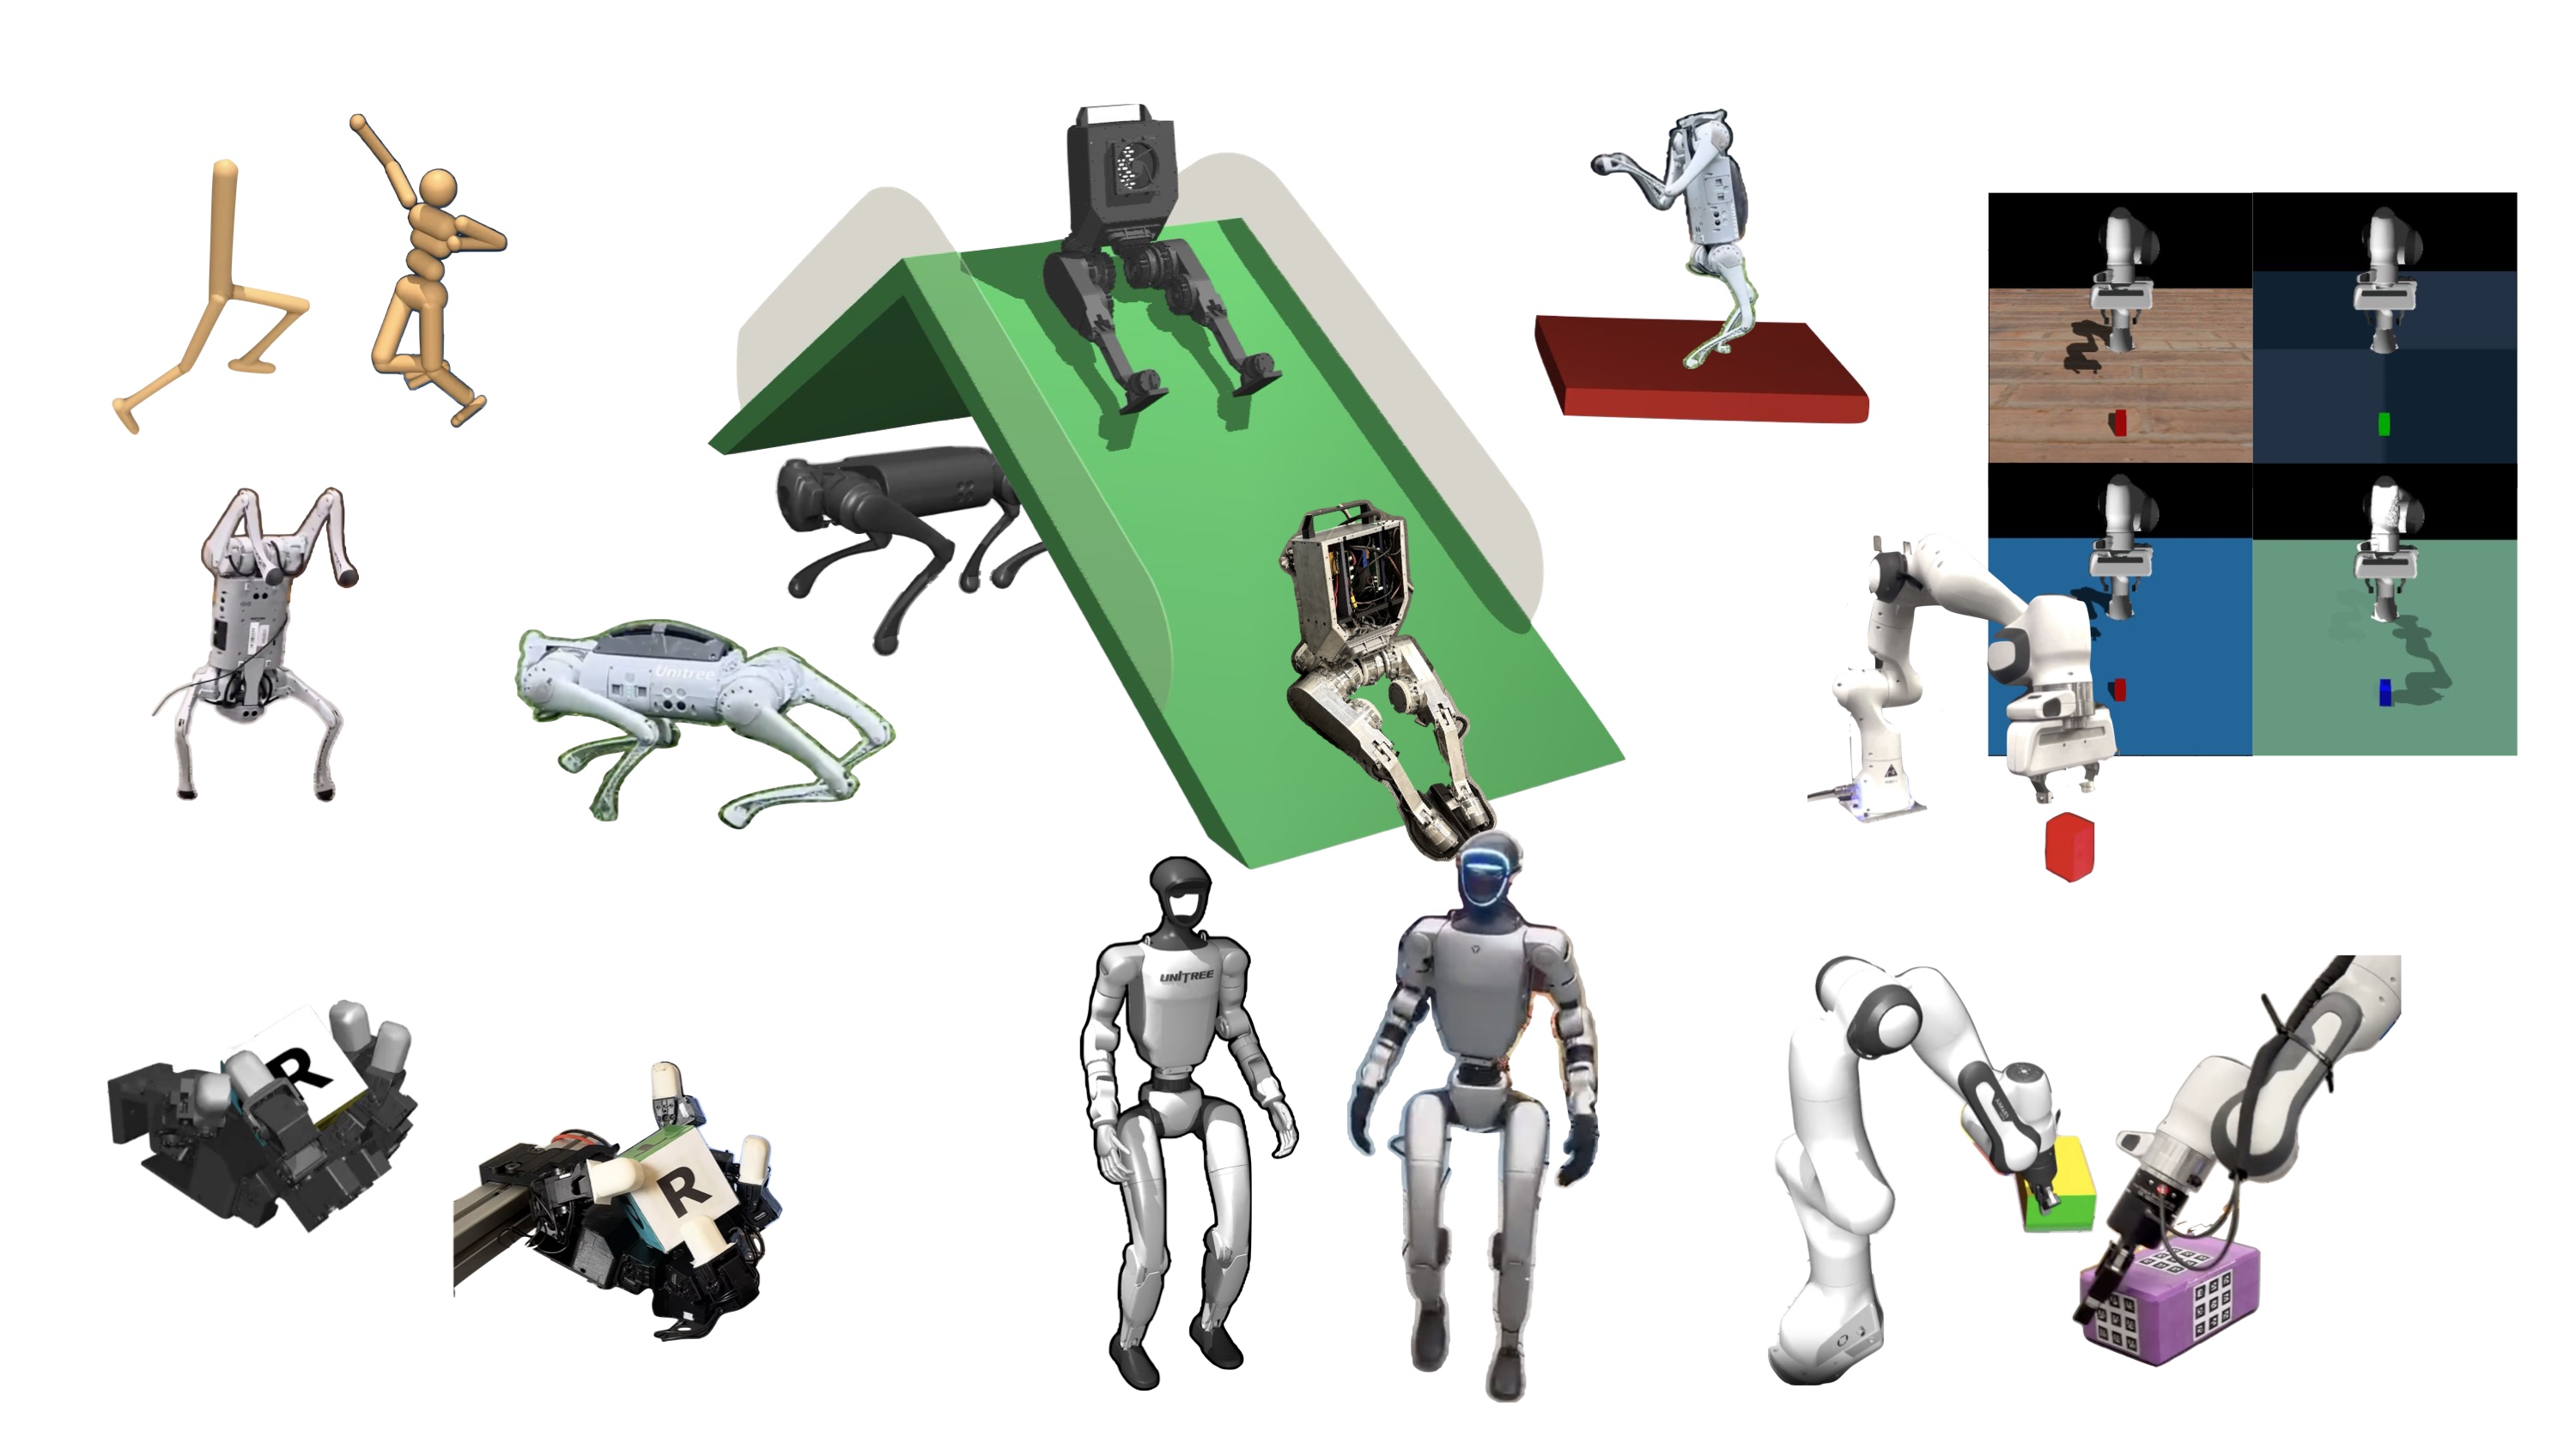
MuJoCo Playground
Kevin Zakka*, Baruch Tabanpour*, Qiayuan Liao*, Mustafa Haiderbhai*, Samuel Holt*, Jing Yuan Luo, Arthur Allshire, Erik Frey, Koushil Sreenath, Lueder A. Kahrs, Carmelo Sferrazza, Yuval Tassa, Pieter Abbeel
Robotics: Science and Systems (RSS) 2025
★ Best Demo Paper Award, RSS ★
Webpage •
Paper •
Code
Berkeley Humanoid A Research Platform for Learning-based Control
Qiayuan Liao, Bike Zhang, Xuanyu Huang, Xiaoyu Huang, Zhongyu Li, Koushil Sreenath
International Conference on Robotics and Automation (ICRA), 2025
Webpage •
Paper •
Code
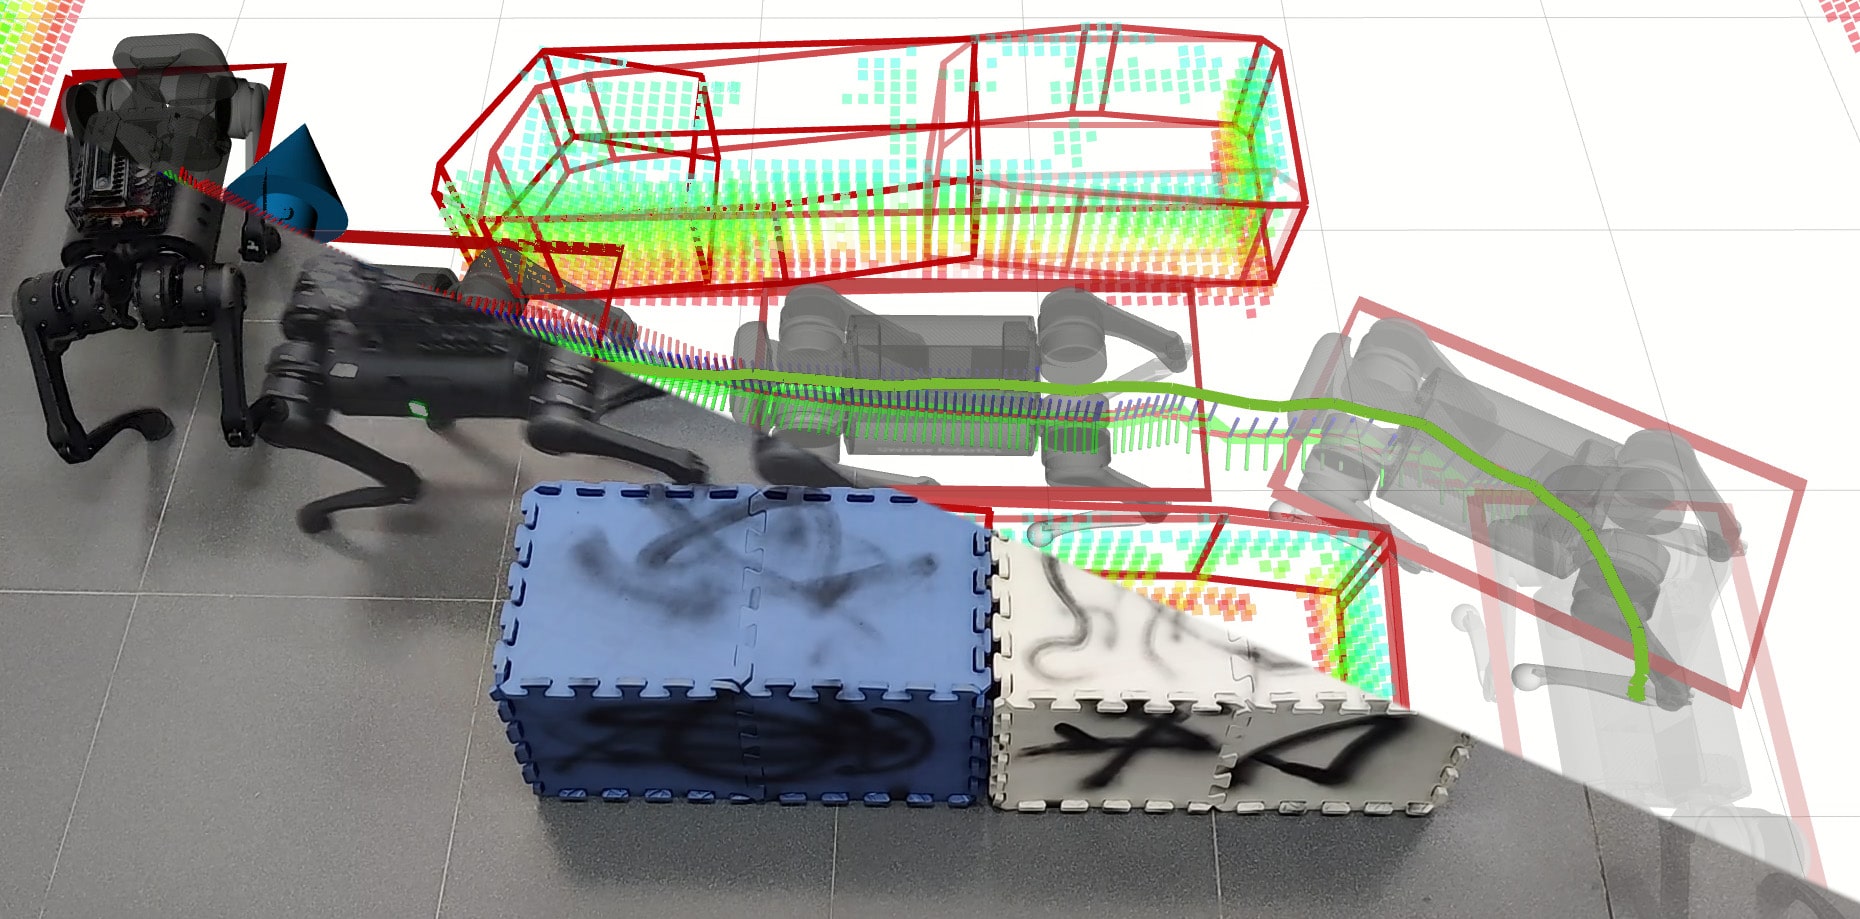
Walking in Narrow Spaces: Safety-critical Locomotion Control for Quadrupedal Robots with Duality-based Optimization
Qiayuan Liao, Bike Zhang, Xuanyu Huang, Xiaoyu Huang, Zhongyu Li, Koushil Sreenath
International Conference on Intelligent Robots and Systems (IROS), 2023
Paper •
Code


will haunt you for the rest of your life.” — System Enhancement Associates, ARC shareware license (1985)
